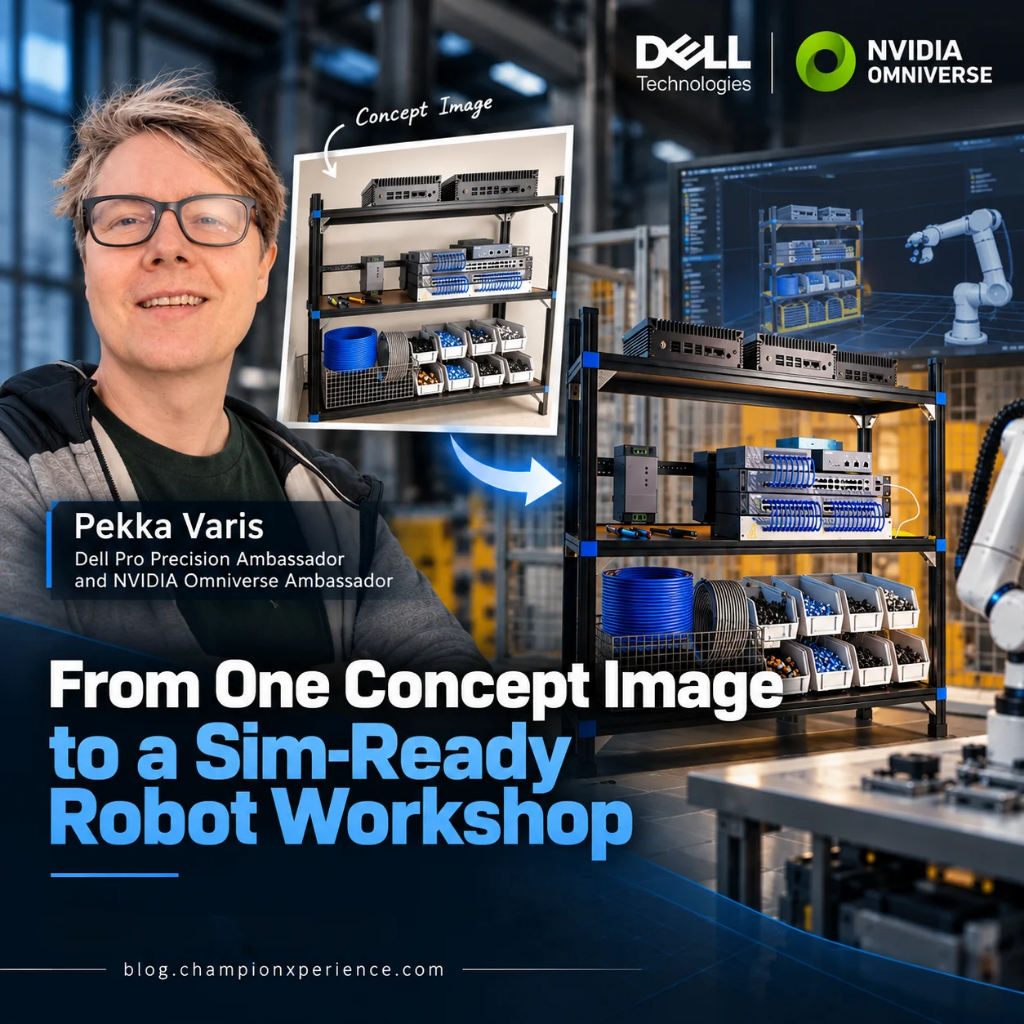
ChampionXperience is pleased to feature Pekka Varis, Dell Pro Precision Ambassador and NVIDIA Omniverse Ambassador, as he shares how he developed Hermes 3D Agent, a workflow that transforms a single concept image into a physically valid NVIDIA Isaac Sim scene, and what he learned about generative 3D for robotics.
A robot that will work in a workshop has to be trained and tested among racks, bins, cables and hand tools long before it meets the real ones. Every one of those objects needs a true size, a mass and a surface the robot can touch. Building such a scene by hand takes an artist weeks. Generative AI can draw the same workshop in seconds, but a picture is not a scene: generated meshes float, pass through each other and come out at the wrong scale.
Hermes 3D Agent is my answer to that gap. You give it one concept image of the space you have in mind. It builds every part in context, sizes it to real-world scale, places it where the picture puts it, and delivers an Isaac Sim scene in which physics has had the last word. Hermes is now in beta. Here is how it works, step by step, and the lessons that apply to anyone building simulation content with generative tools.
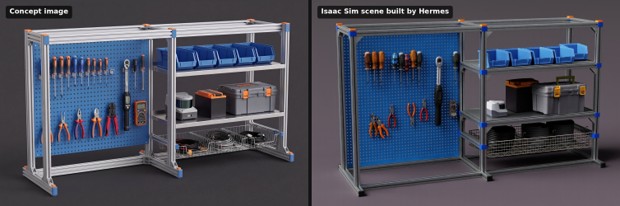 Left: the concept image. Right: the Isaac Sim scene Hermes built from it, with every part at real-world scale.
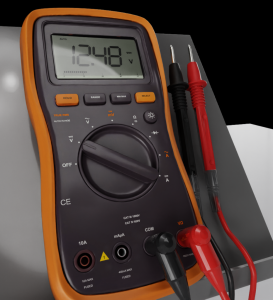
Labels, buttons and the LCD under its cover glass are real Blender geometry, so they stay sharp in close-ups.
5. Physics has the last word. Items are lowered to half a millimetre above their support and settled with PhysX in Isaac Sim. A Blender pass then pulls each item back toward its place in the design without breaking contact. Hermes simulates cables as rods using the Newton physics engine. For example, ten EV charging cables with Type 2 plugs settle into their wire baskets in 5.4 seconds. Their length changes by less than 1%.
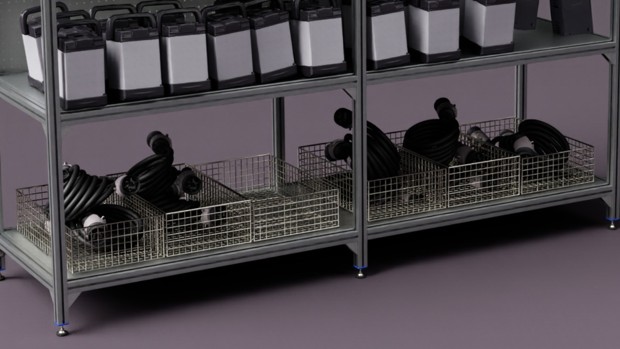 EV charging cables with Type 2 plugs, simulated with Newton and settled in their wire baskets.
6. Checks run before a person looks. Every build passes structure, inventory, contact, colour and overlay gates and gets two scores: intent (does it match the picture?) and physical validity (does it stand up?). A build that fails goes back for another fix round; only builds that pass reach a person.
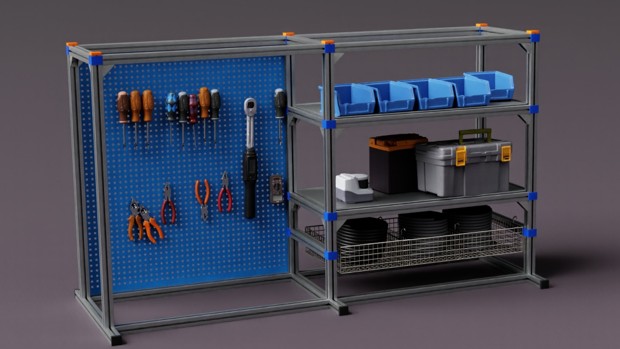 A finished Hermes rack in Isaac Sim: Blender-built frame, library tools and bins, simulated cables.
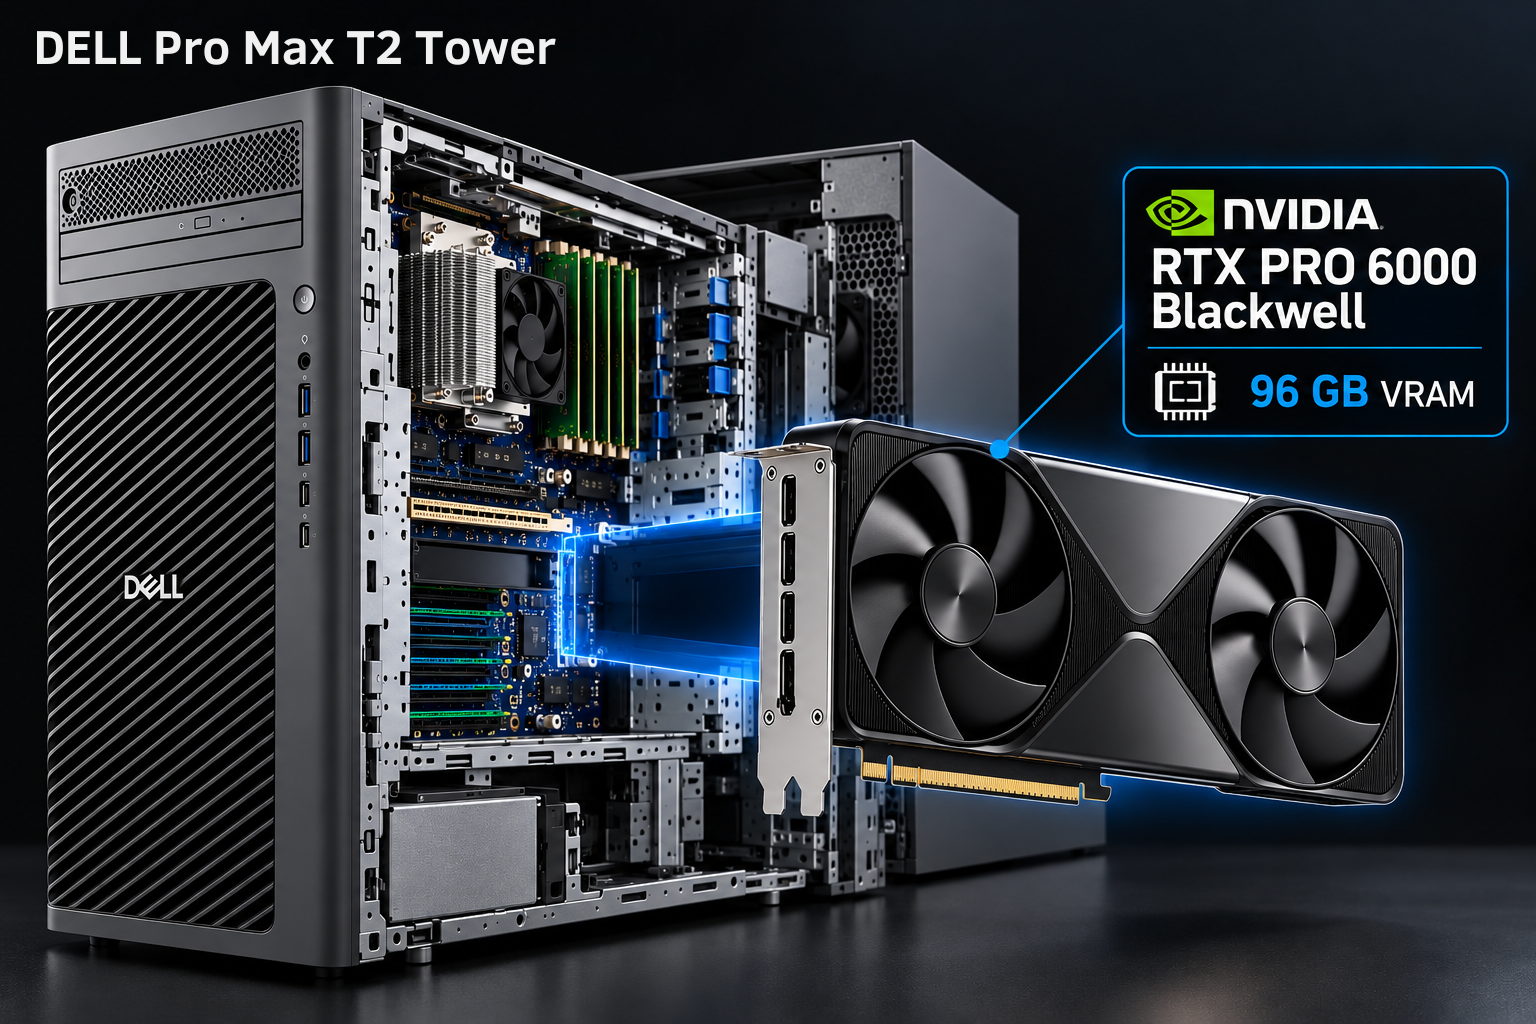
All of this development ran on a Dell Pro Max T2 tower with an NVIDIA RTX PRO 6000 Blackwell. Its 96 GB of GPU memory keeps Isaac Sim, Blender, the detection models and the scene resident at once, with no swapping between tools. A second workstation with an RTX 6000 Ada builds racks in parallel from a shared job queue. Keeping everything local speeds up iteration. When I change a rule, I can rebuild the scene and test it in Isaac Sim within minutes.
With Persona AI, we brought humanoid welding robots into a shipyard digital twin using NVIDIA Omniverse. The robots were trained in Isaac Lab. We rendered the scene on the same Dell and NVIDIA hardware for the NVIDIA GTC 2026 keynote.
Watch the Persona AI video. Read Persona AI’s story, the Dell Technologies article, or the Cineshare case study.
Workshops are just the beginning. Hermes 3D Agent can help you create many types of environments for robotics simulation and training. If your team builds simulation scenes, digital twins or robot-training environments, apply for the Hermes beta and send one concept image of the space you need.